HARVIER POC + 5 HARVIX
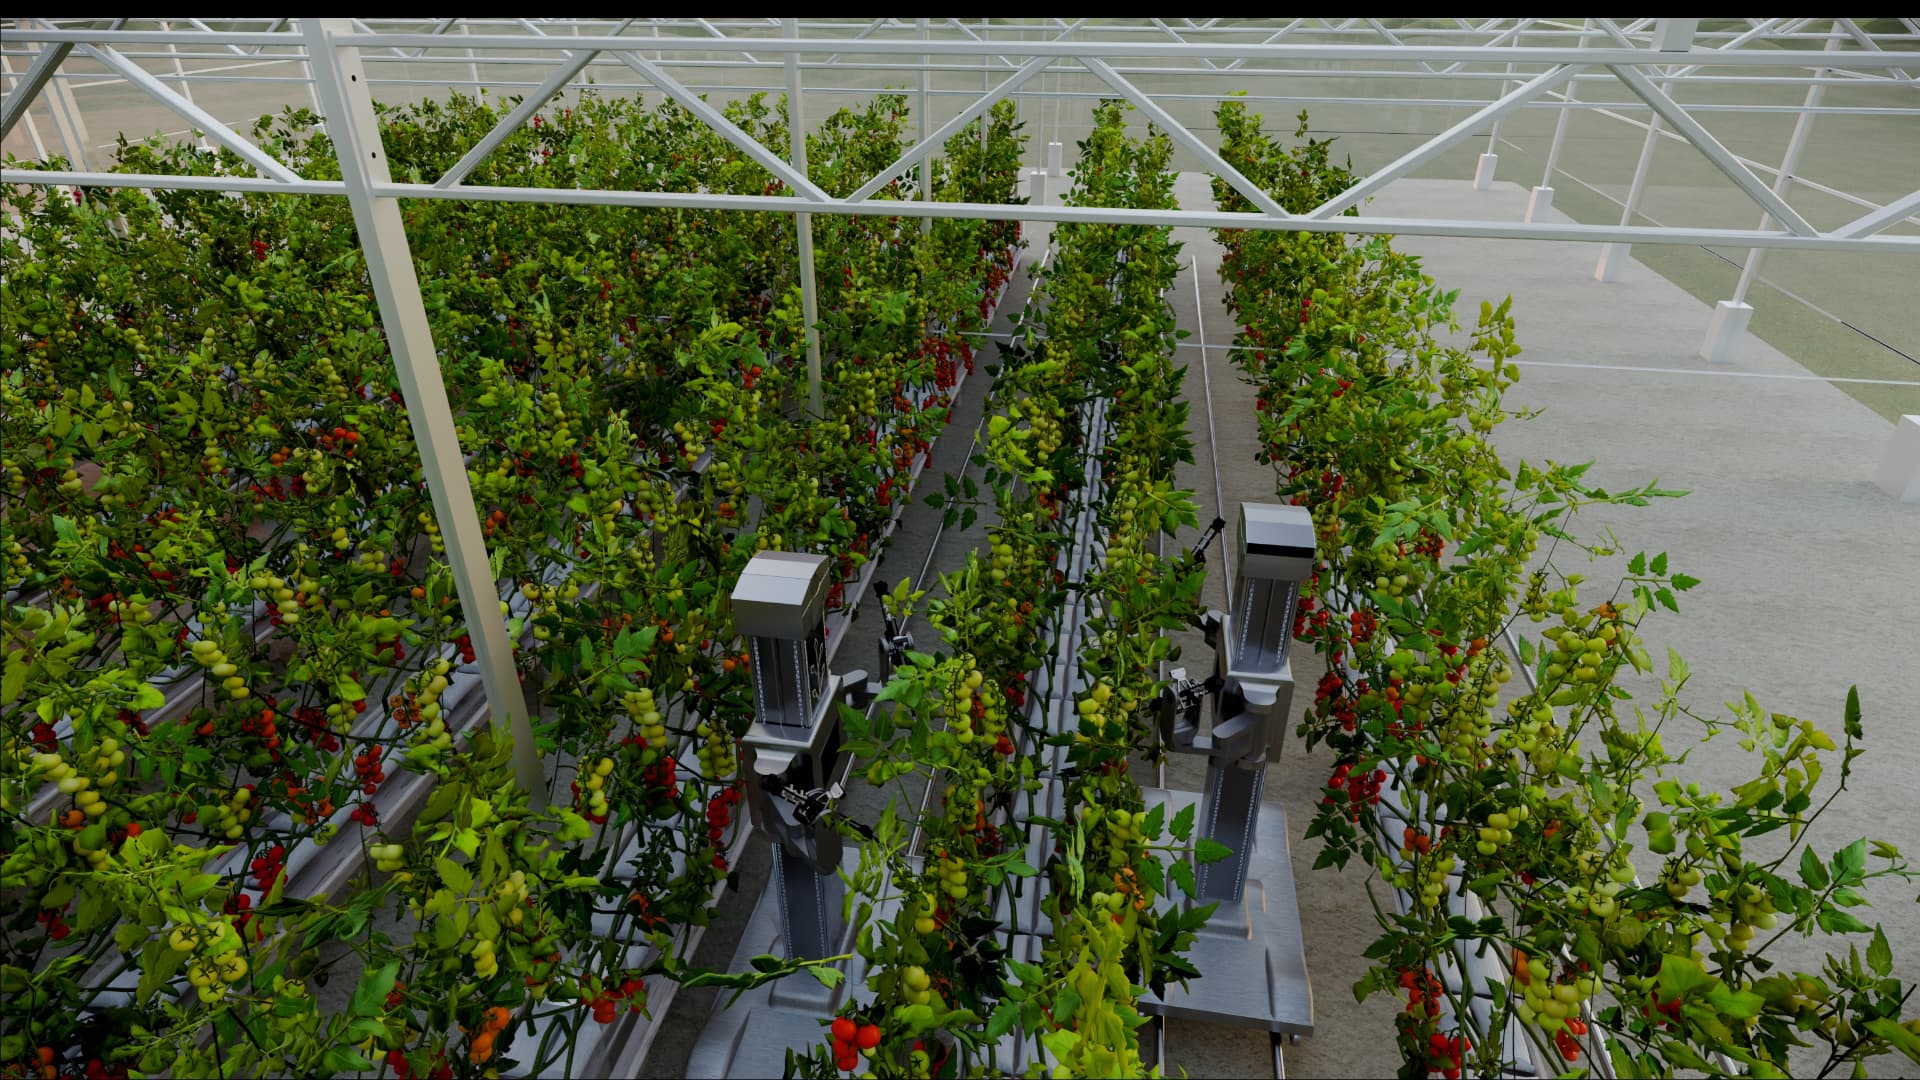
1 teleoperator controls 5 robots
HARNIX is focused on harvesting cherry-tomatoes in high-intensity, year-round glasshouses in the Netherlands, backed by remote human judgment from Moldova. The planned service is priced per kilogram harvested.
Robot handles repeatable work
Teleoperator resolves exceptions
Grower pays per kg
The planned system routes difficult moments to trained teleoperators working from Moldova.
The commercial model uses minimal upfront investment and recurring payment tied to harvested kilograms.
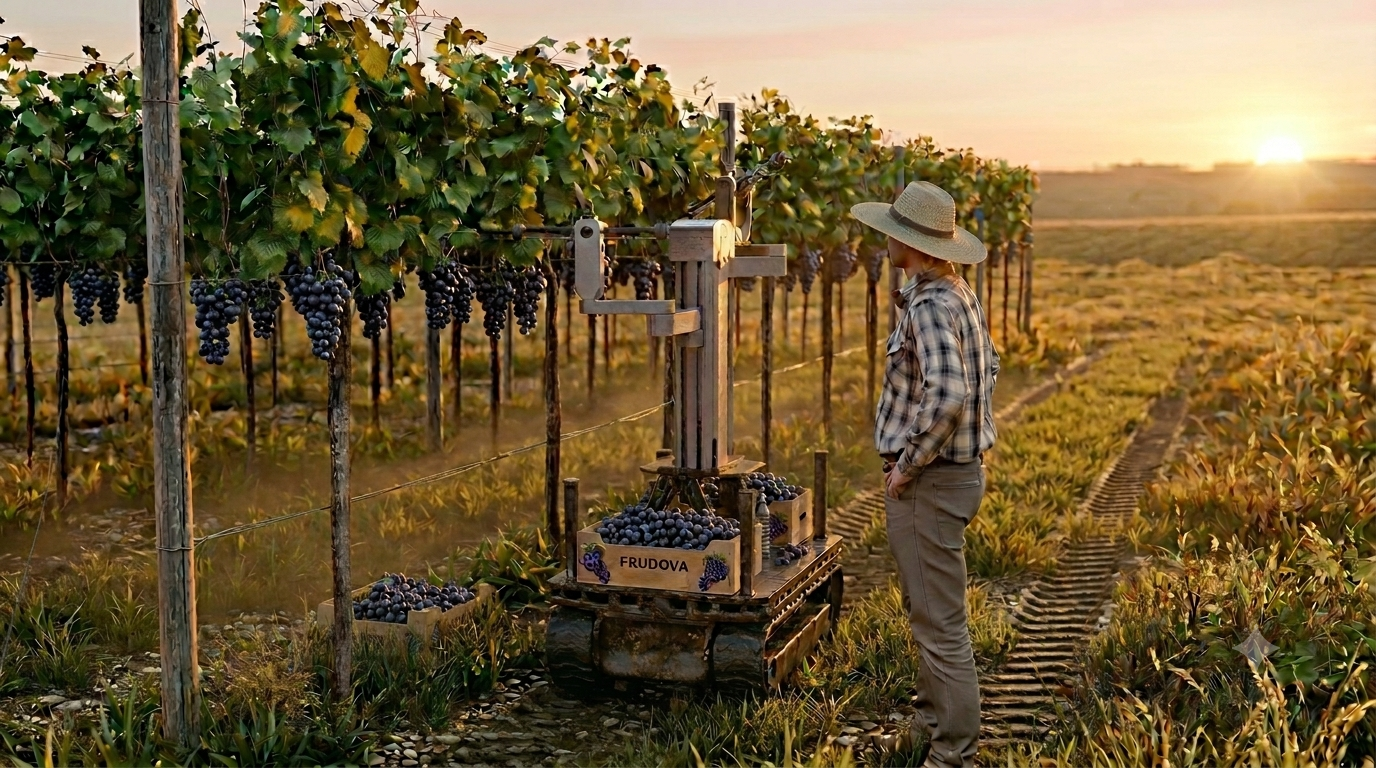
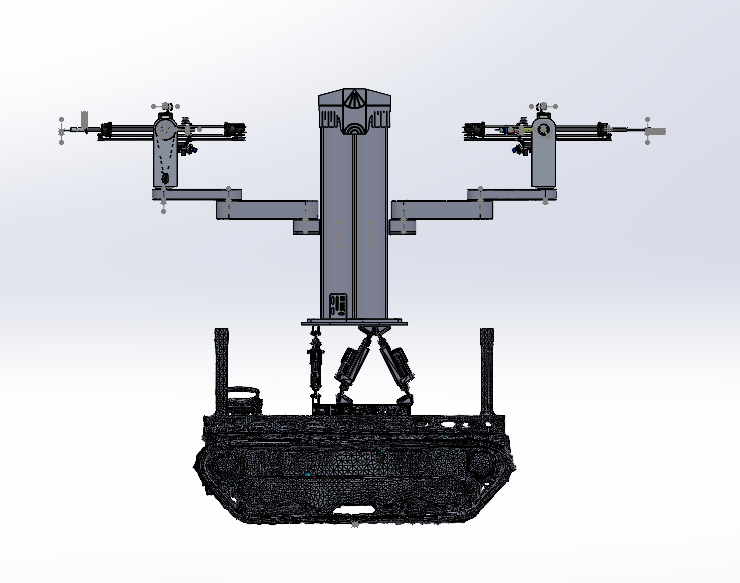
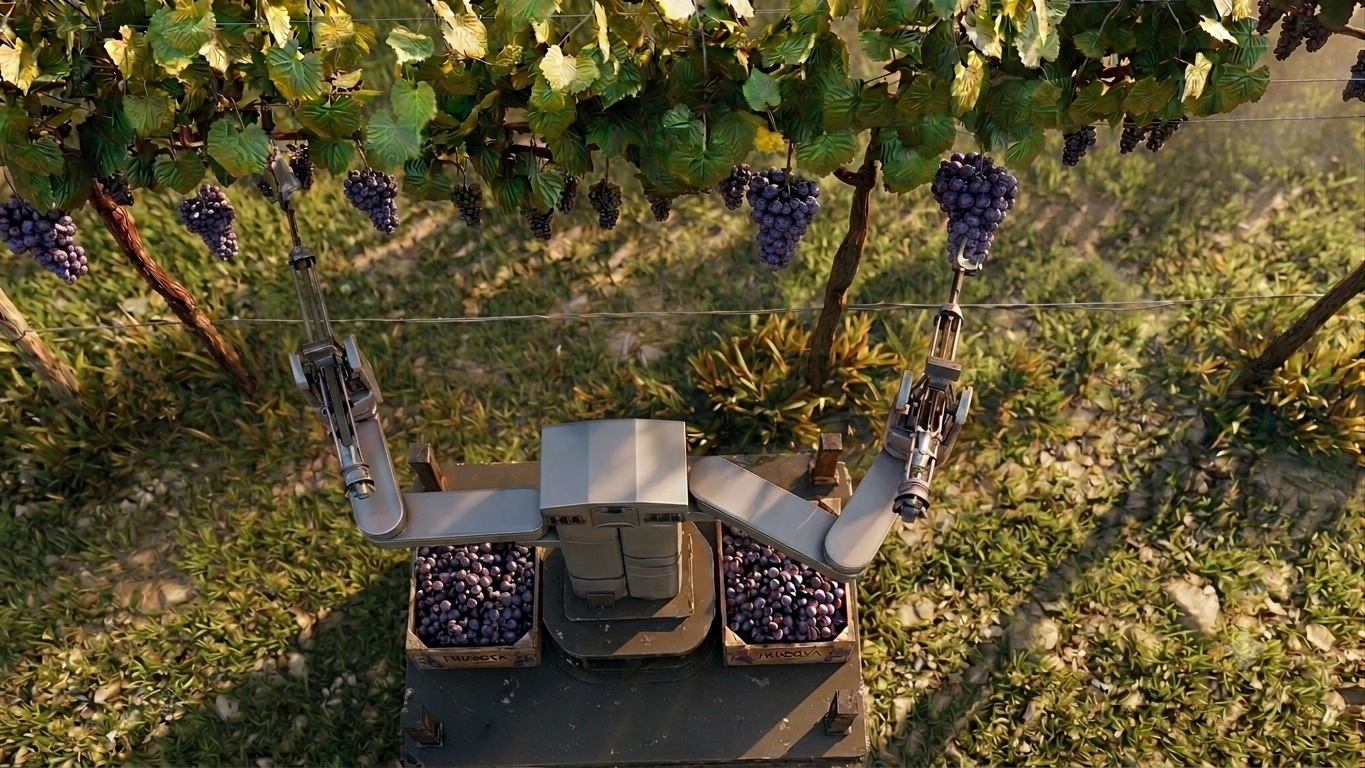
HARVIER, our proof of concept, is built around field reality: narrow rows, fragile produce, and short harvesting windows.
High-value crop growers face three linked pressures: scarce labor, narrow harvest windows and the high upfront cost of equipment.
HARNIX is being developed to provide harvest capacity as a service. The aim is more predictable access to harvesting.
// BIGGER THAN COST SAVINGS — EVERY FARM THAT SCALES EXPANDS OUR MARKET
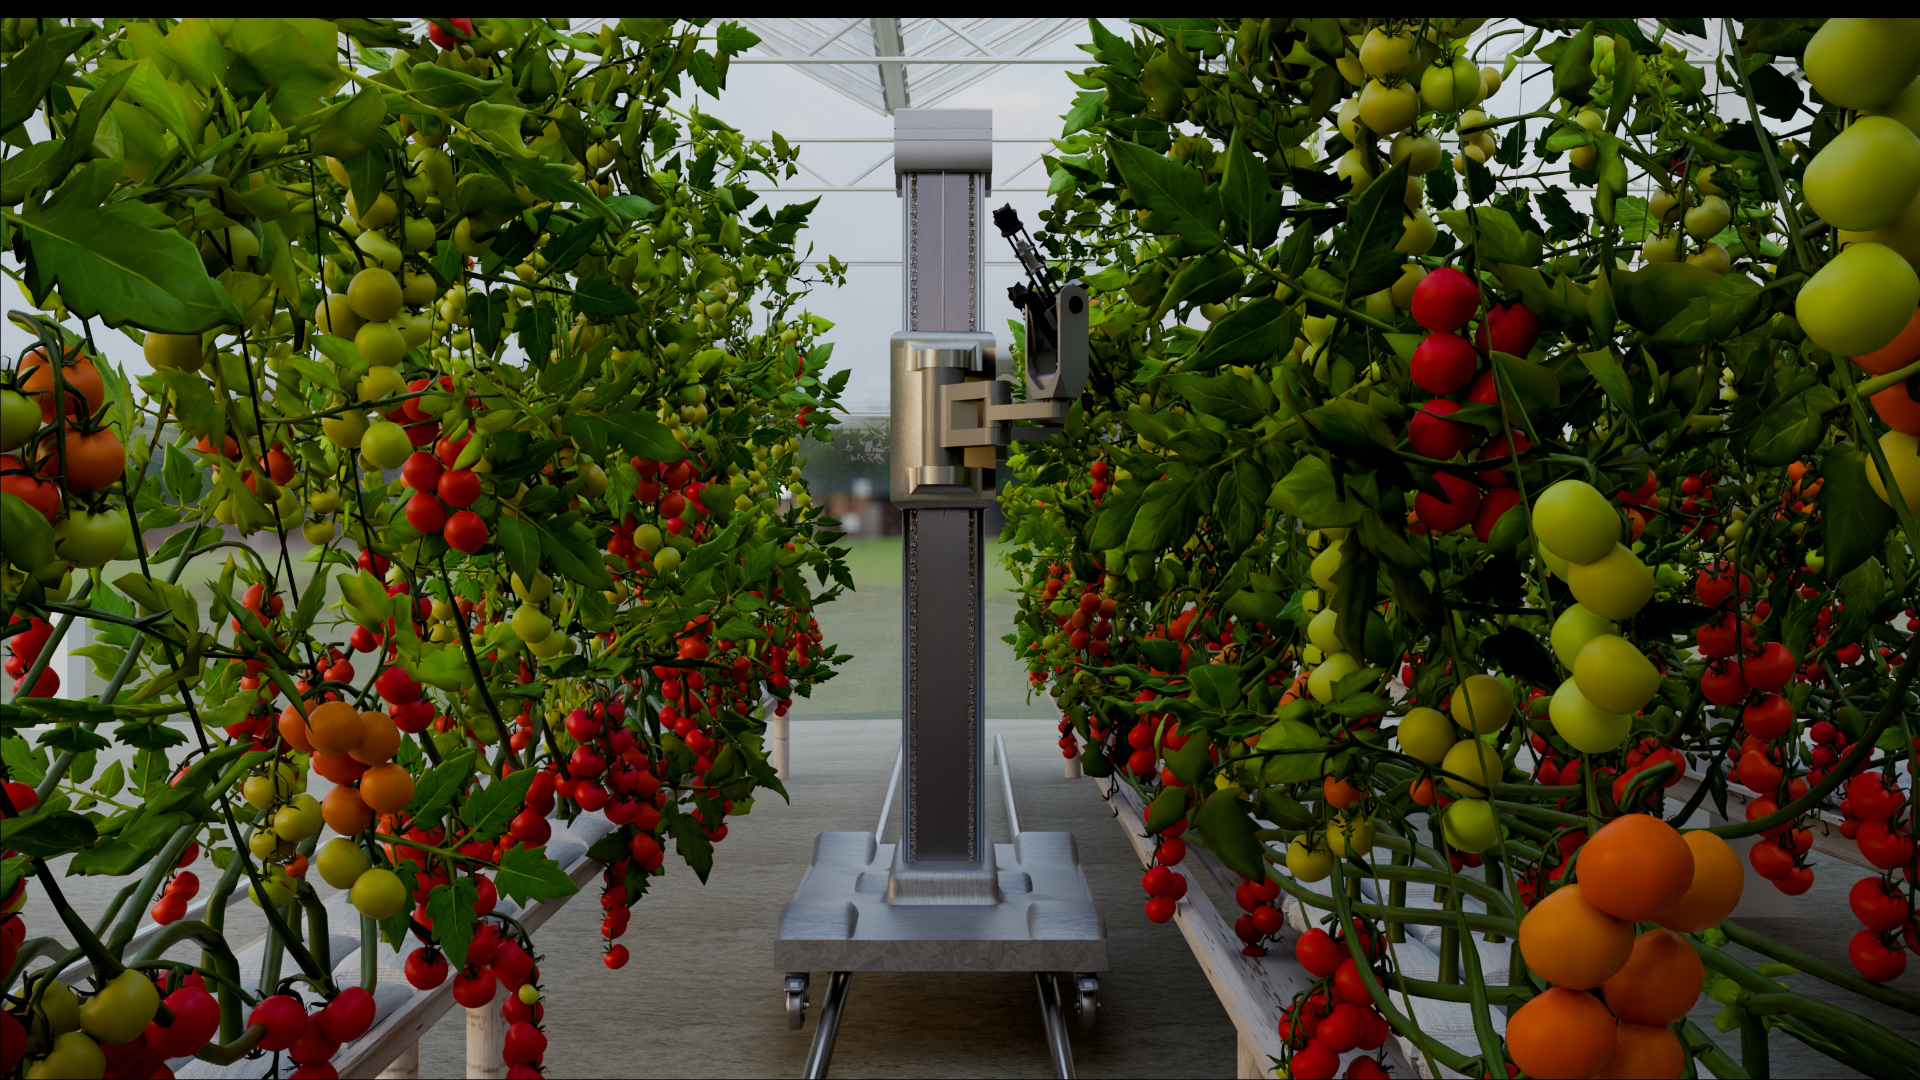
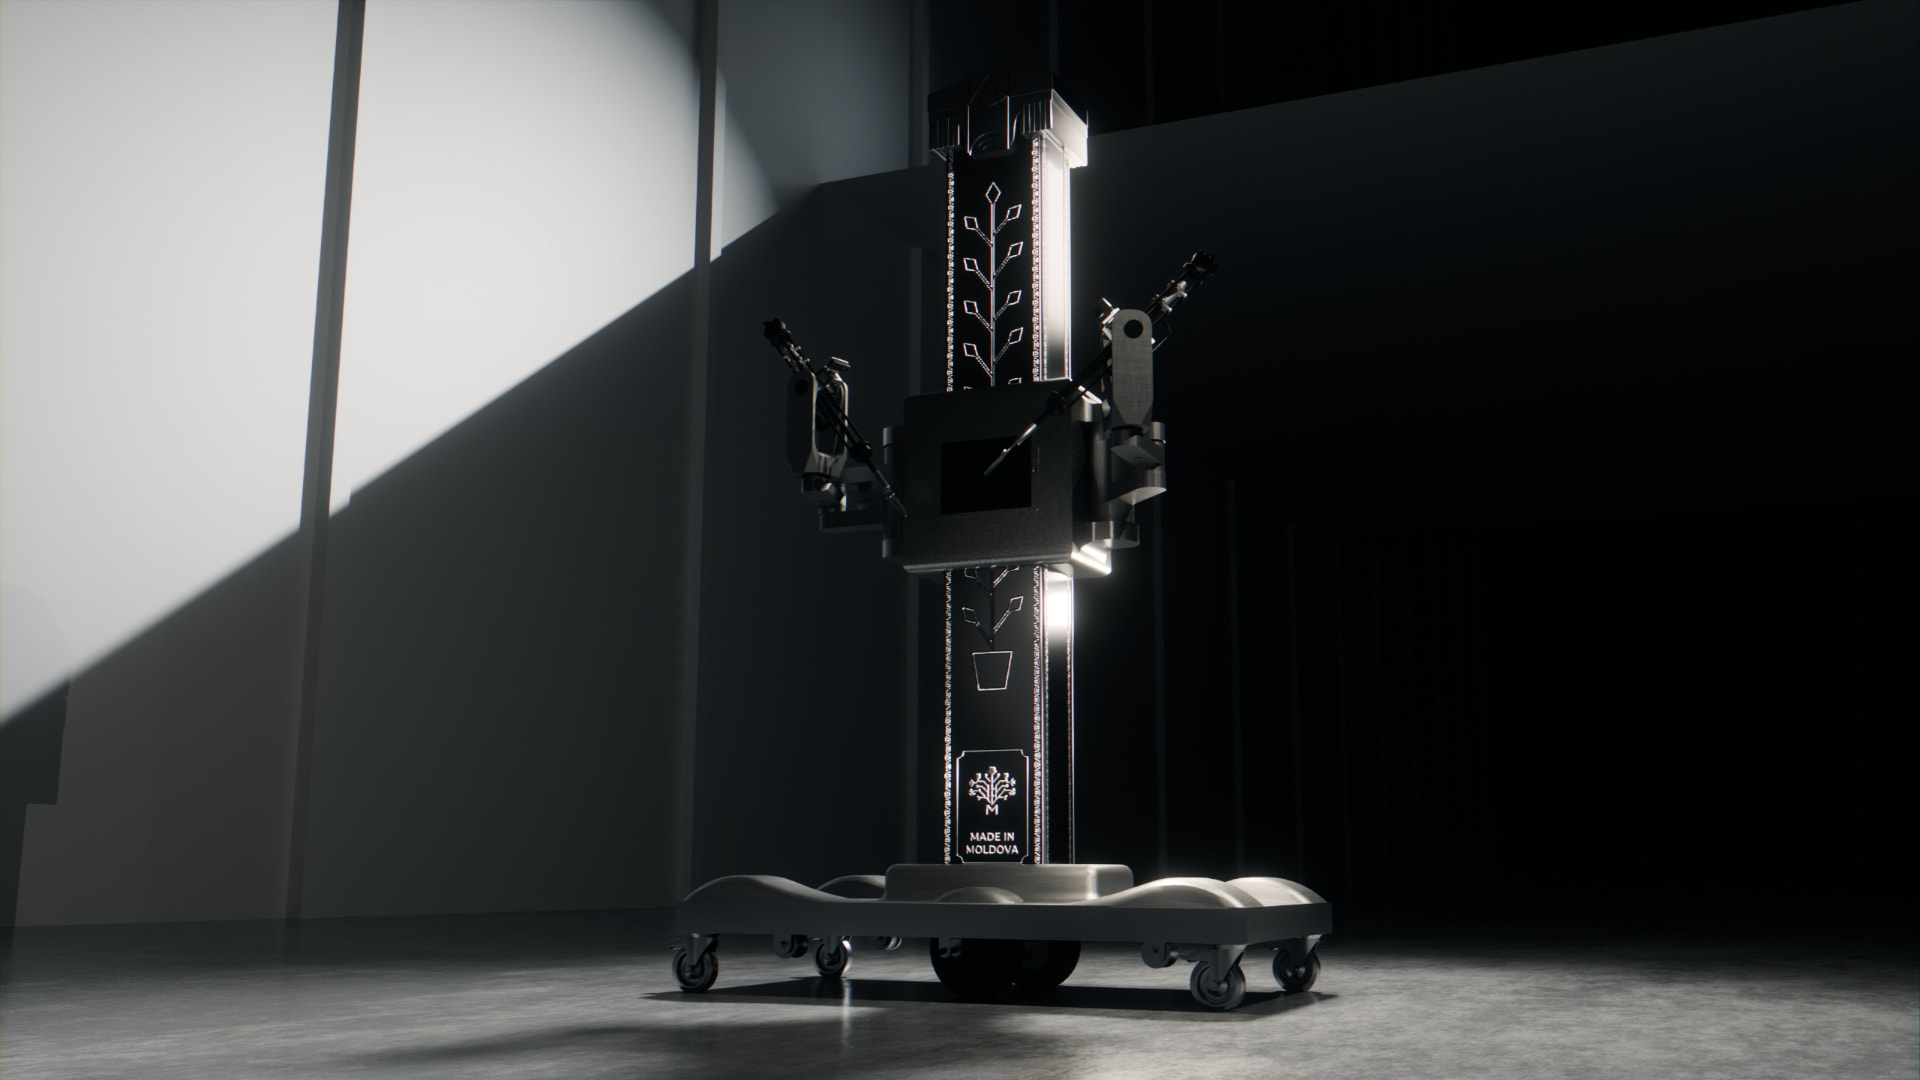
A pipe-rail greenhouse telerobot for tomatoes, with the tracked vineyard platform proving the technology in the field.
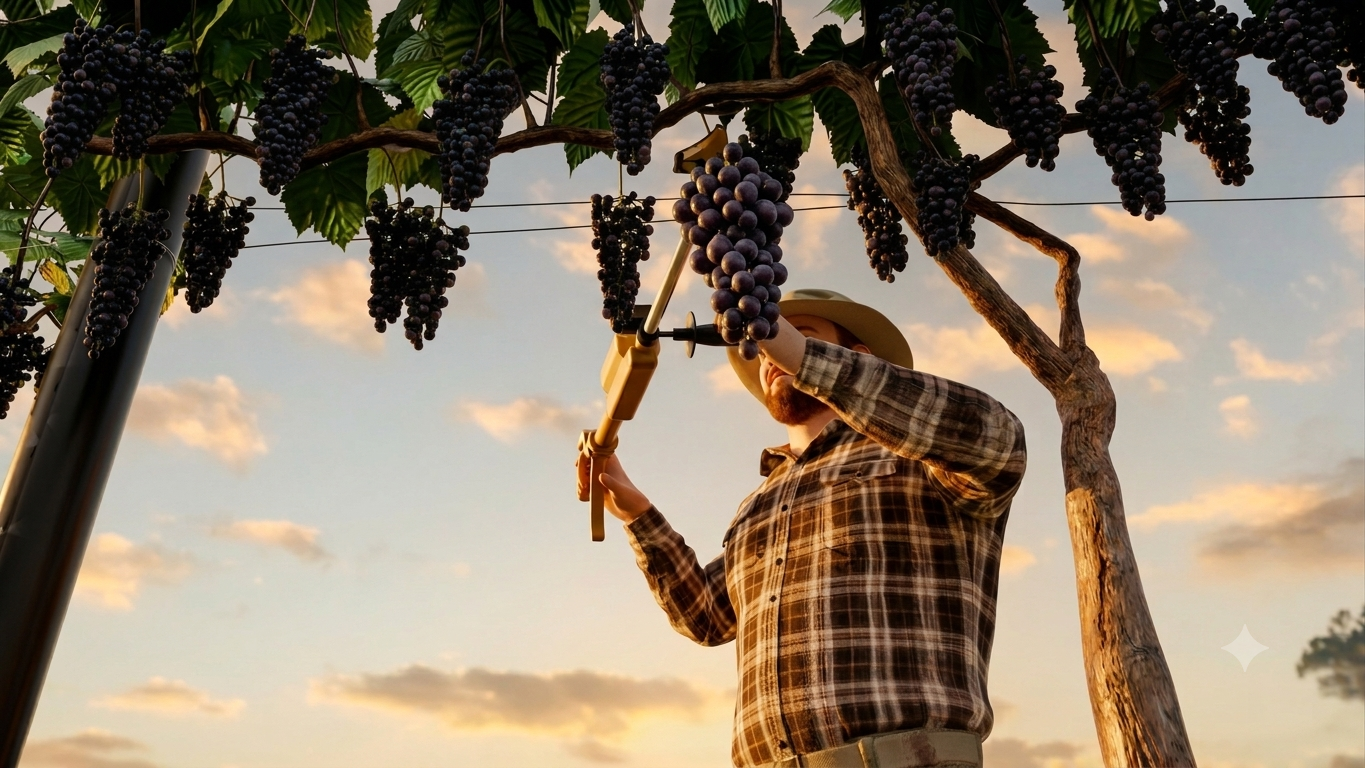
A human uses HARPOON to harvest while the custom instrument records training data for the AI.
Repeatable work is automated first; difficult moments are routed to trained teleoperators.
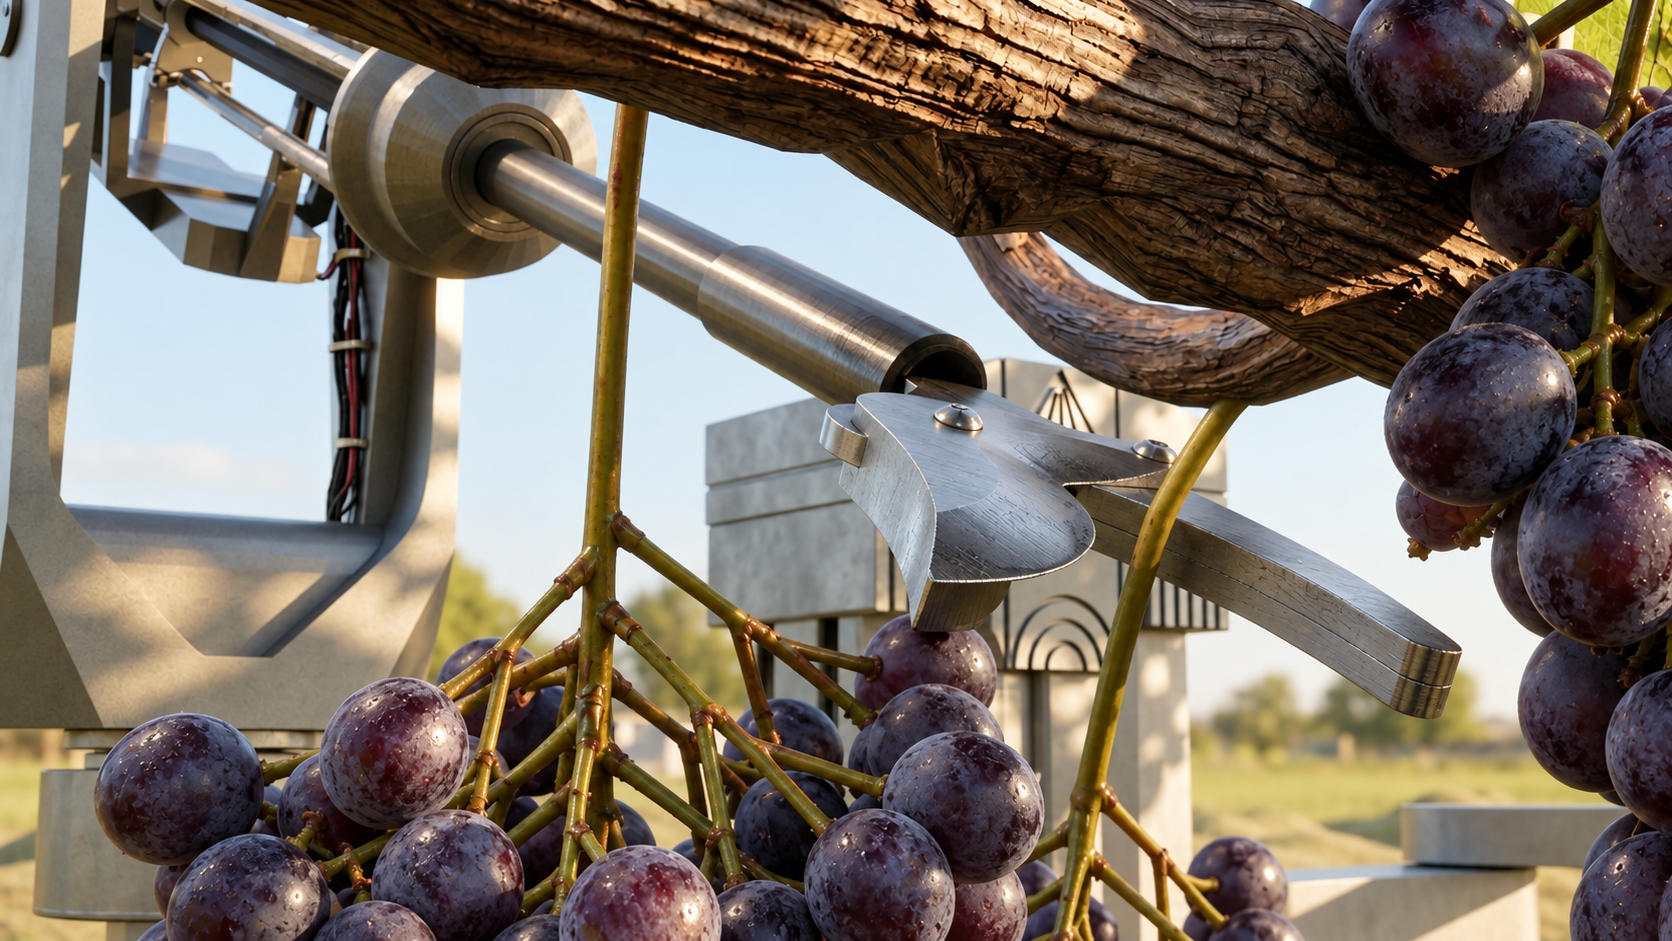
The planned system automates repeatable work first and routes difficult moments to trained teleoperators in Moldova. Field data is intended to improve autonomy over time.
HARPOON records human harvesting actions to build the dataset needed to train the AI; future teleoperator interventions are planned as a second data stream.
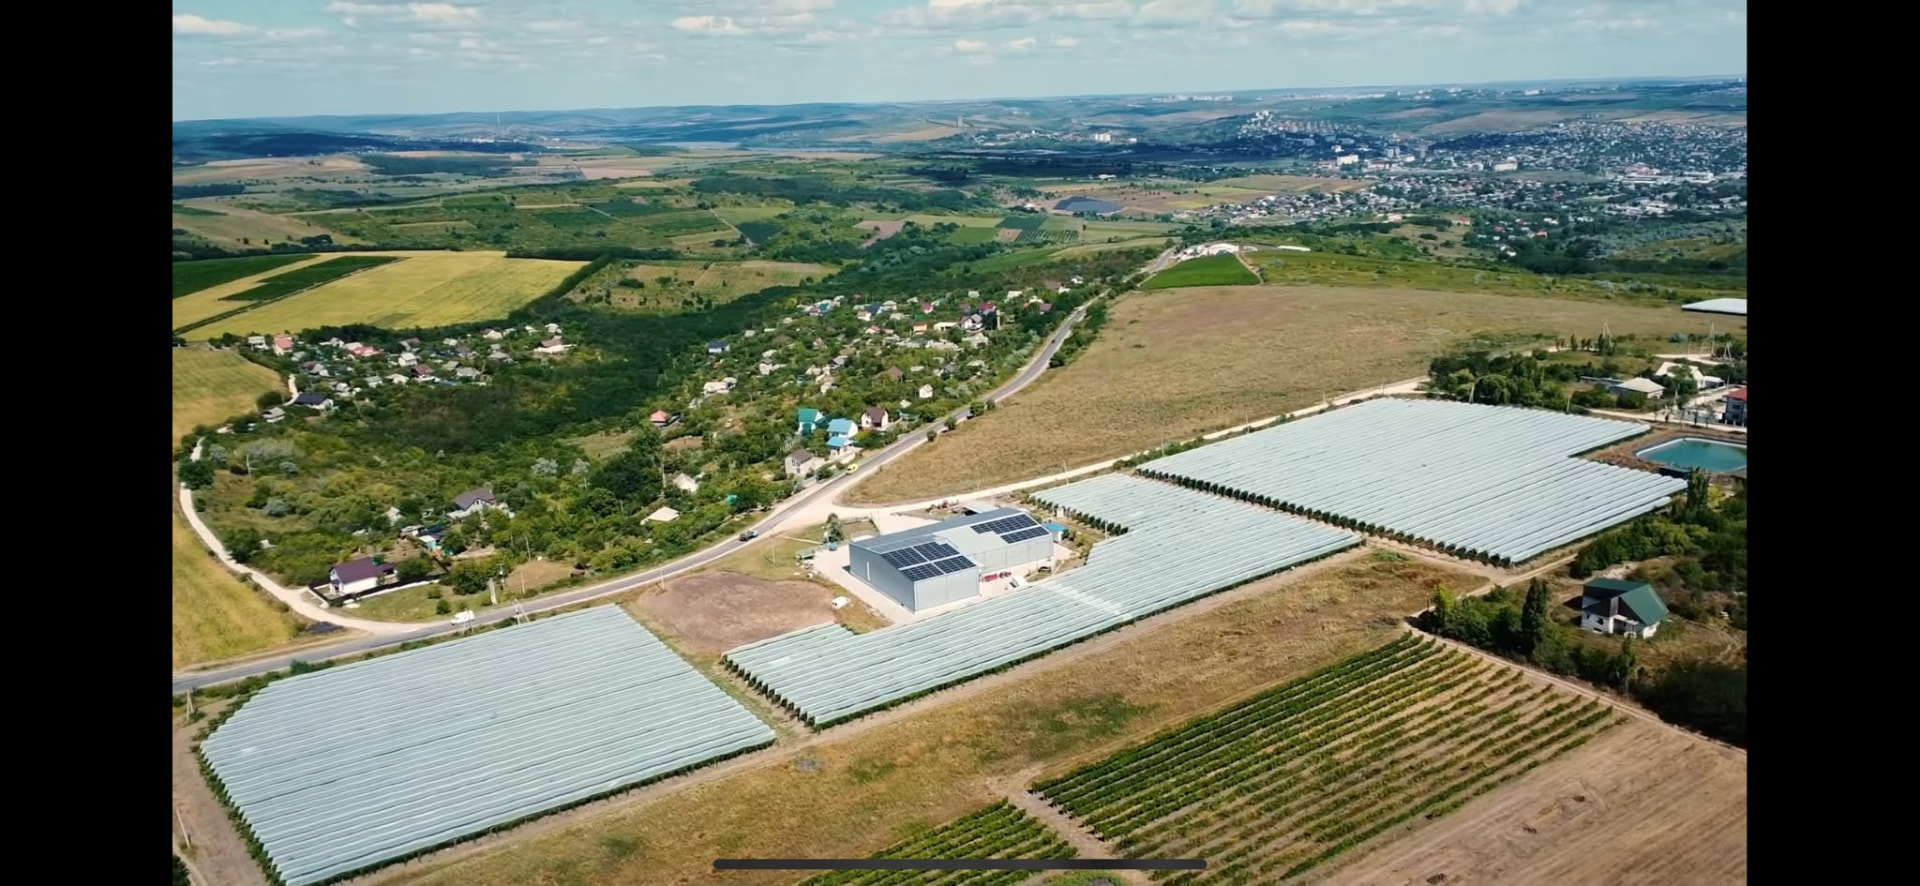
Frudova, Moldova's largest table-grape exporter, gives HARNIX direct field access, operational feedback and connections to growers across Europe.
These are illustrative calculator scenarios, not achieved results. Beachhead market — tomato greenhouses in the Netherlands.
You can use our harvesting economics calculator to test different assumptions and scenarios.
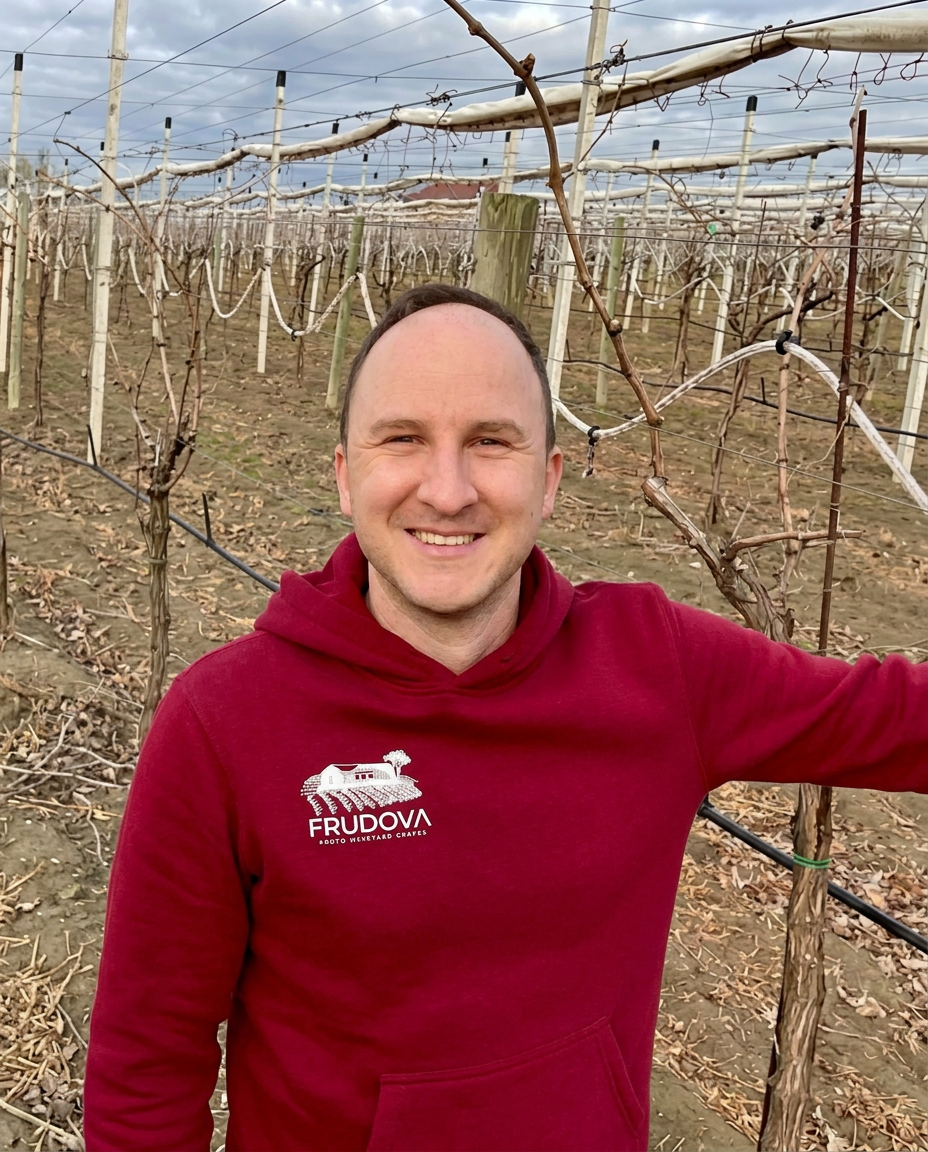
CEO of HARNIX and co-founder of Frudova, the strategic partner providing field access, operational feedback and a wider European grower network.

Graduated from MIT in 2020, worked at top robotics labs while in university, and has 4 years of robotics industry experience, including building, programming and testing harvesting robots.
Current product work includes HARPOON field data collection and HARVIX and HARVIER prototype buildout.
This first round funds prototype buildout and field data. The planned next $2.5M seed round funds a 50-robot deployment.